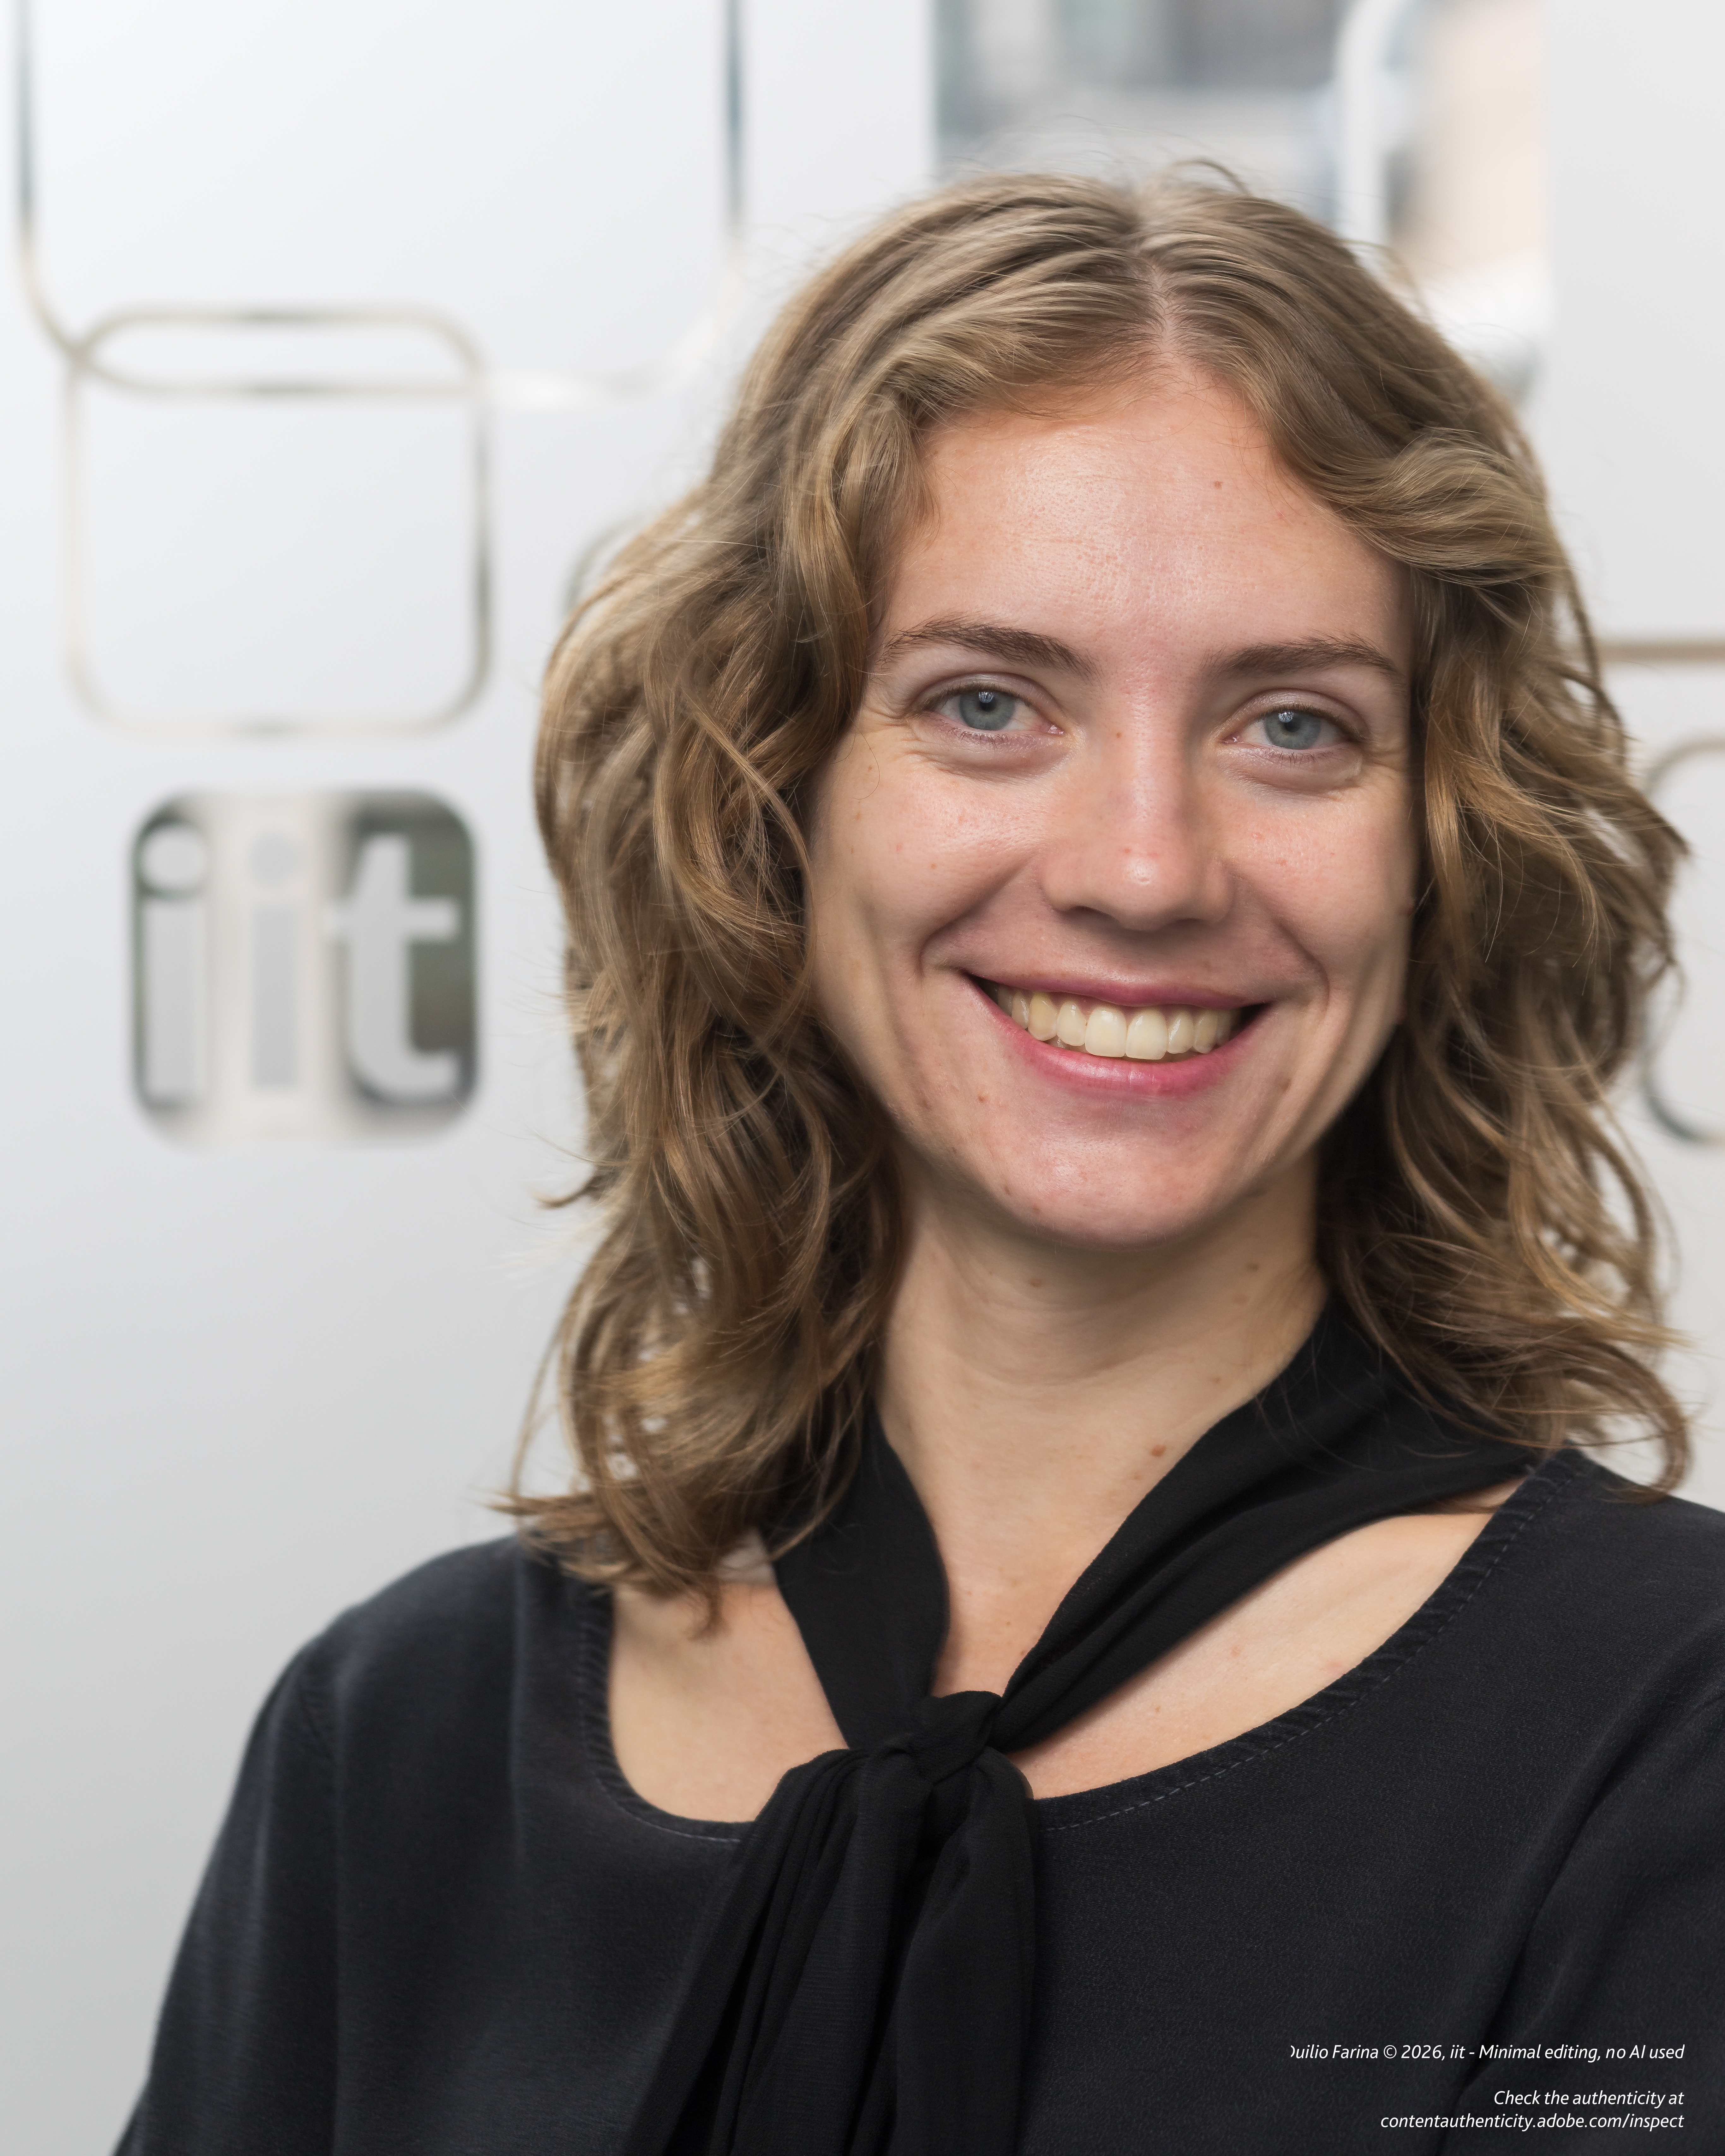
Evelyn D’Elia
PhD Student, Italian Institute of Technology and University of Manchester
Studying how physical priors and model-based techniques can be leveraged to improve the quality of legged robot locomotion policies. In particular, I’m interested in morphological symmetries and Koopman theory applied to reinforcement learning.
About me
I have been at the Italian Institute of Technology since 2022 when I started a position as a research fellow in the Artificial and Mechanical Intelligence (AMI). Since 2023 I have been working toward my PhD in physics-informed learning for legged robot policies. Since 2026 I have been continuing this research with the Sustainable Artificial Intelligence Lab (SAIL). Before that, I completed my M.S. in Systems and Control in 2021 at Delft University of Technology in the Netherlands. My master thesis, “Automatic Controller Selection on a Humanoid Robot using Optimization Techniques”, was done at the LARSEN lab at INRIA Nancy - Grand Est, France. I earned my B.S. degree in Mechanical Engineering in 2019 from Northeastern University in Boston.